ANTHONY NISTOR // STACKR

Stackr Differential Drive

A small squared-off robot that packs two driven wheels, a caster, a battery, and a purpose-built controller into one printed chassis.

// SYSTEM ARCHITECTURE

How Stackr Is Put Together

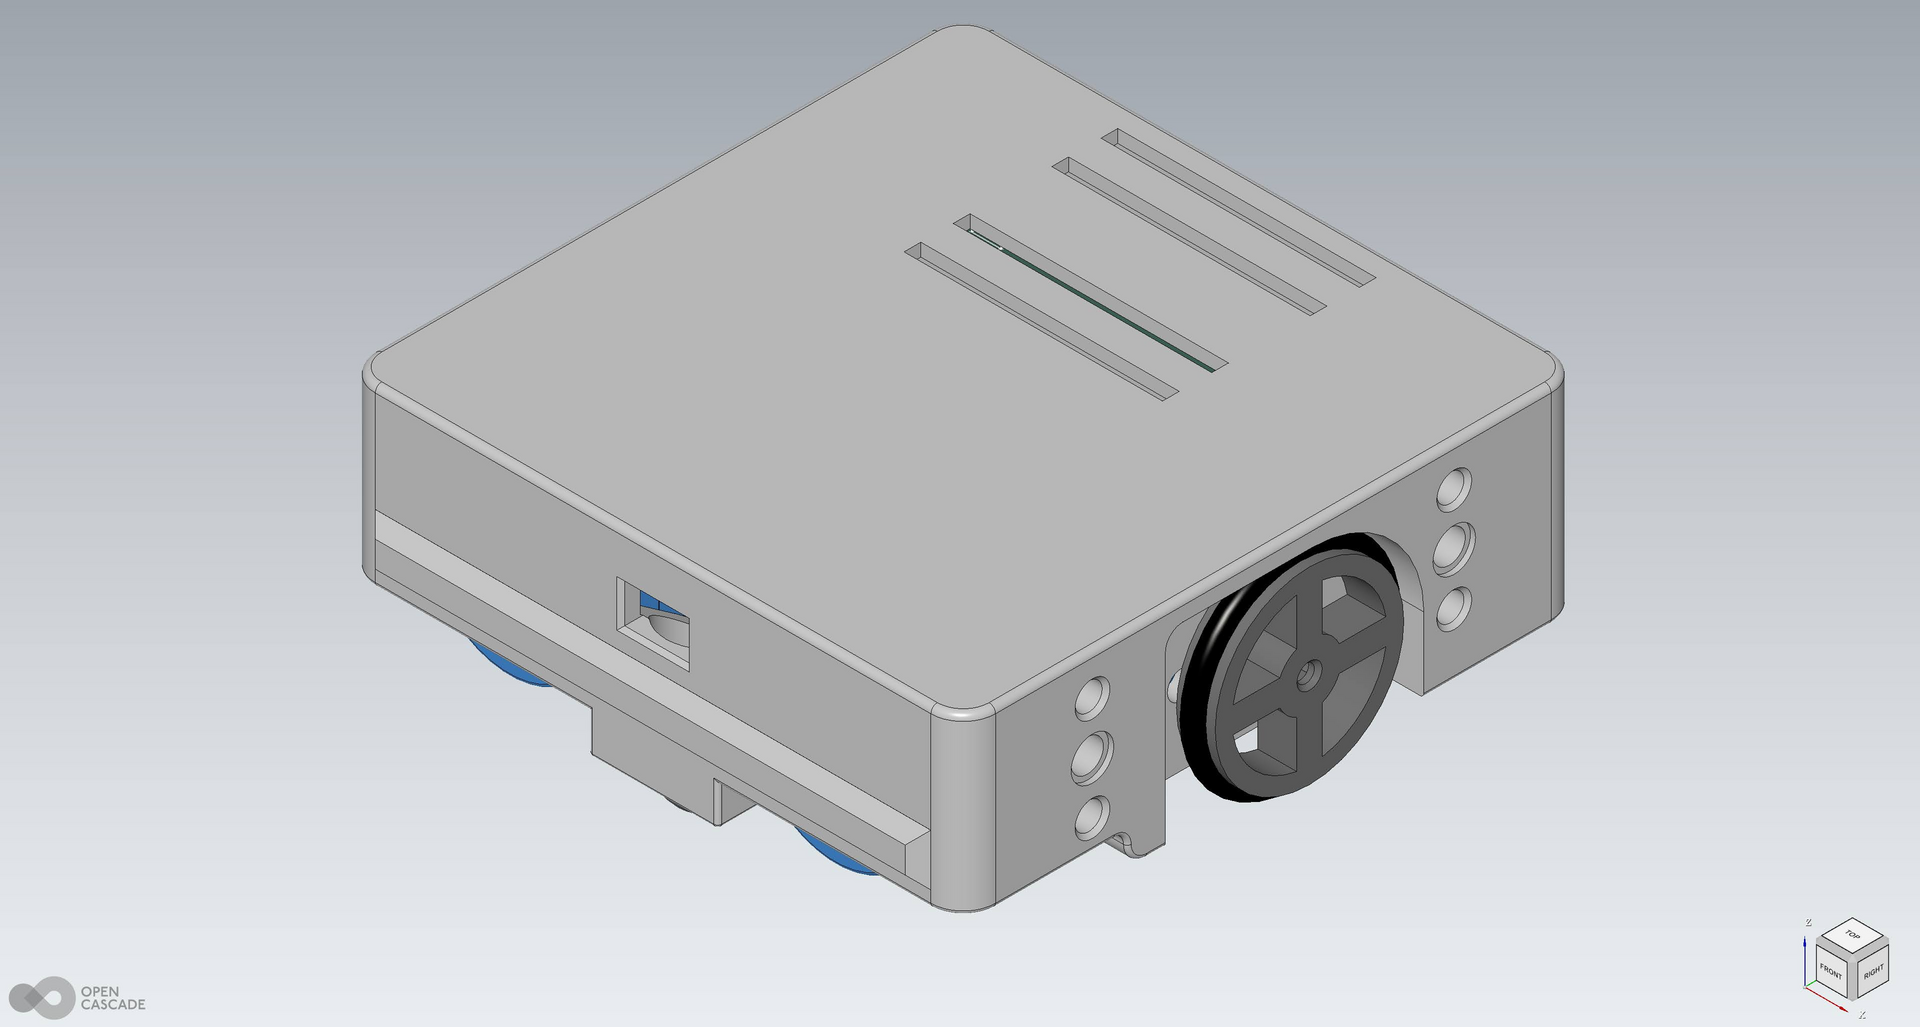
The chassis was revised in CAD as a DIY Alvik-style body, then printed and fitted with a custom driver board. An Arduino-compatible Nano sits on headers so the robot can be programmed from the top deck.

  • Differential Drive Two gear motors turn the wheels. A ball caster carries the opposite end of the shell.
  • Printed Chassis The body has top vents, service holes beside the wheels, and room for the battery and controller.
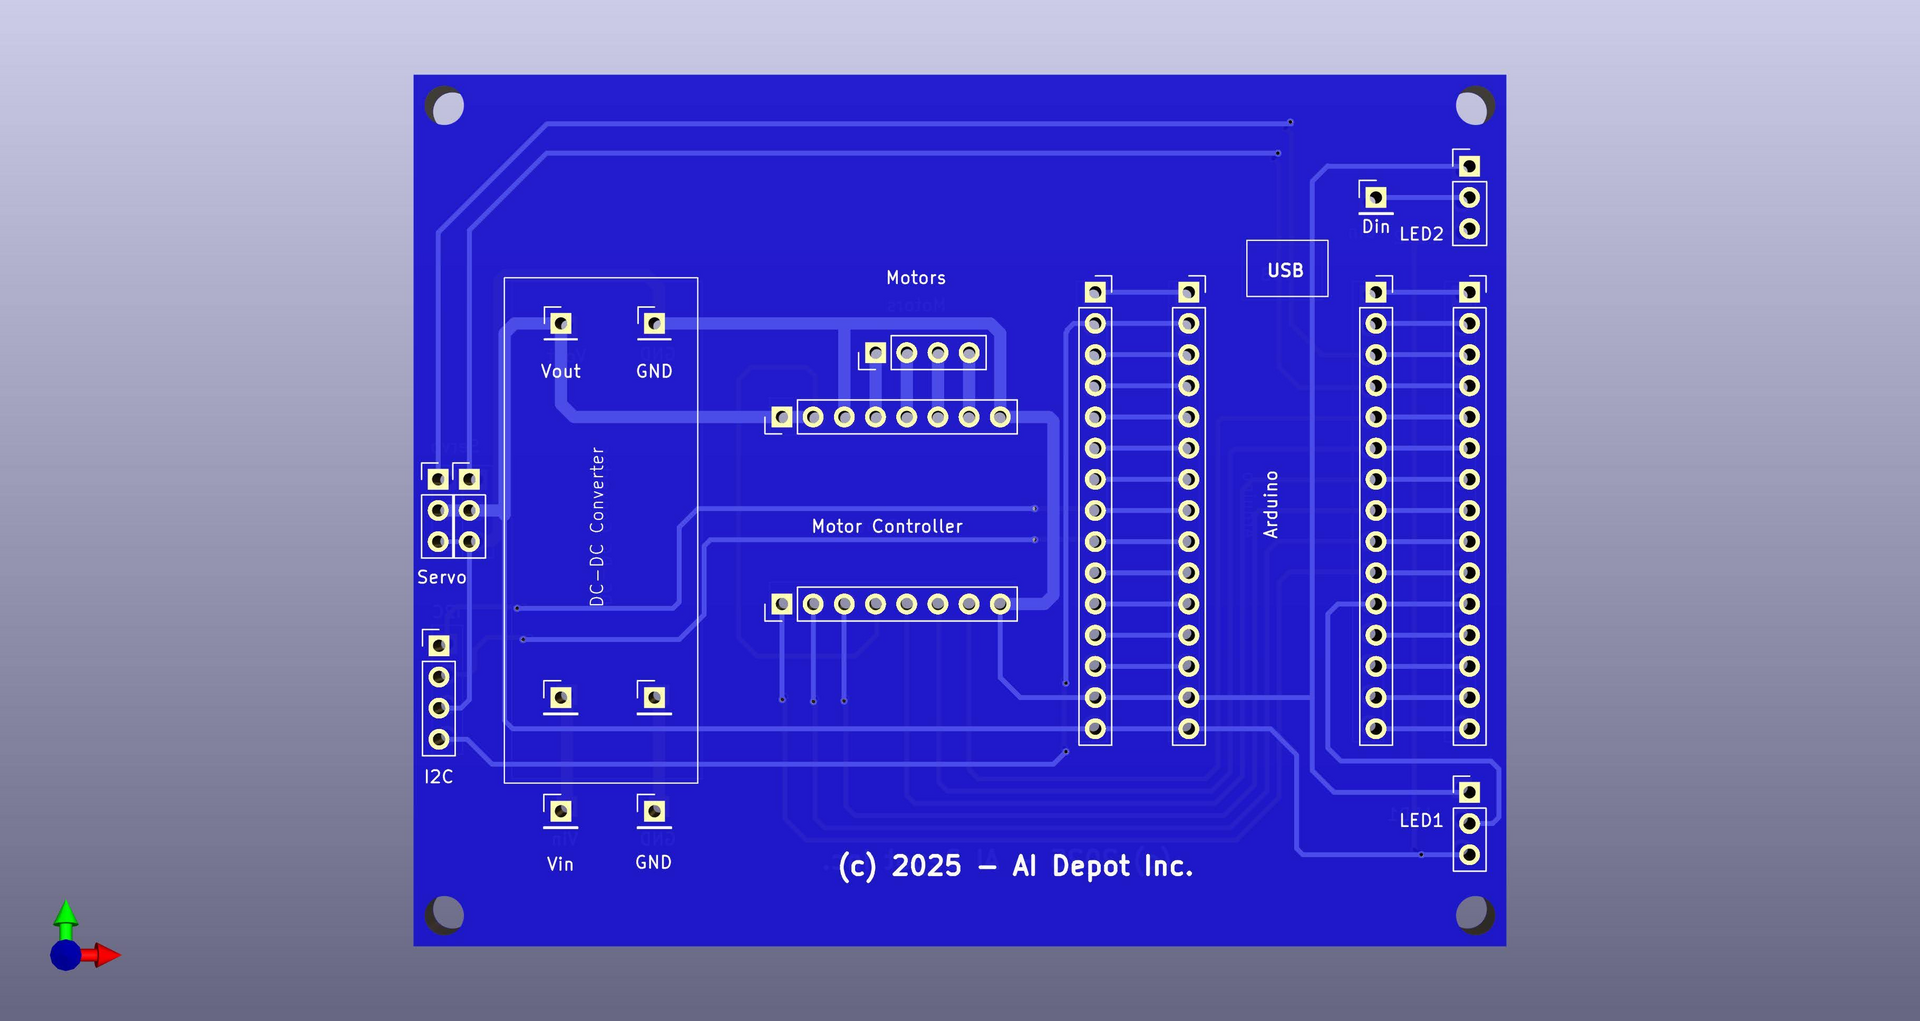
  • Custom Driver Board The PCB provides an Arduino footprint, motor driver, power input, a DC-DC converter, a servo header, and I2C. The board is marked AI Depot Inc.
STACKR_ASSEMBLY.LOG ACTIVE
1. BATTERY

18650 cell through the converter on the driver board

POWER
↓ Regulated rail
2. DRIVER PCB

Motor controller and Arduino footprint

BOARD
↓ Motor outputs
3. DRIVE

Two gear motors and the front caster

MOTION
// DESIGN WALKTHROUGH

Chassis Cutaway

The archive has no running video for this revision. The CAD cutaway is the demonstration of how the drive and sensors sit in the shell.

CHASSIS_CUTAWAY.PNGREV V4

Motors, Caster, and Controller

The cutaway shows the gear motors side by side, shafts running out to the wheels, and a downward-looking sensor ahead of the ball caster. A separate board render places the Arduino, motor controller, and power parts on one PCB.

// HARDWARE & SOFTWARE

System Component Breakdown

01

Printed Shell

White chassis and lid, with vents and openings for the wheel hardware.

02

Gear Motors

A matched pair driving printed wheels and rubber tires.

03

Driver PCB

Custom board with motor driver, converter, servo header, and an Arduino footprint.

04

Nano

Arduino-compatible controller mounted on headers on the top deck.

// PROJECT MEDIA

Build Photographs & Drawings

From loose parts, through the closed shell, to the installed controller.
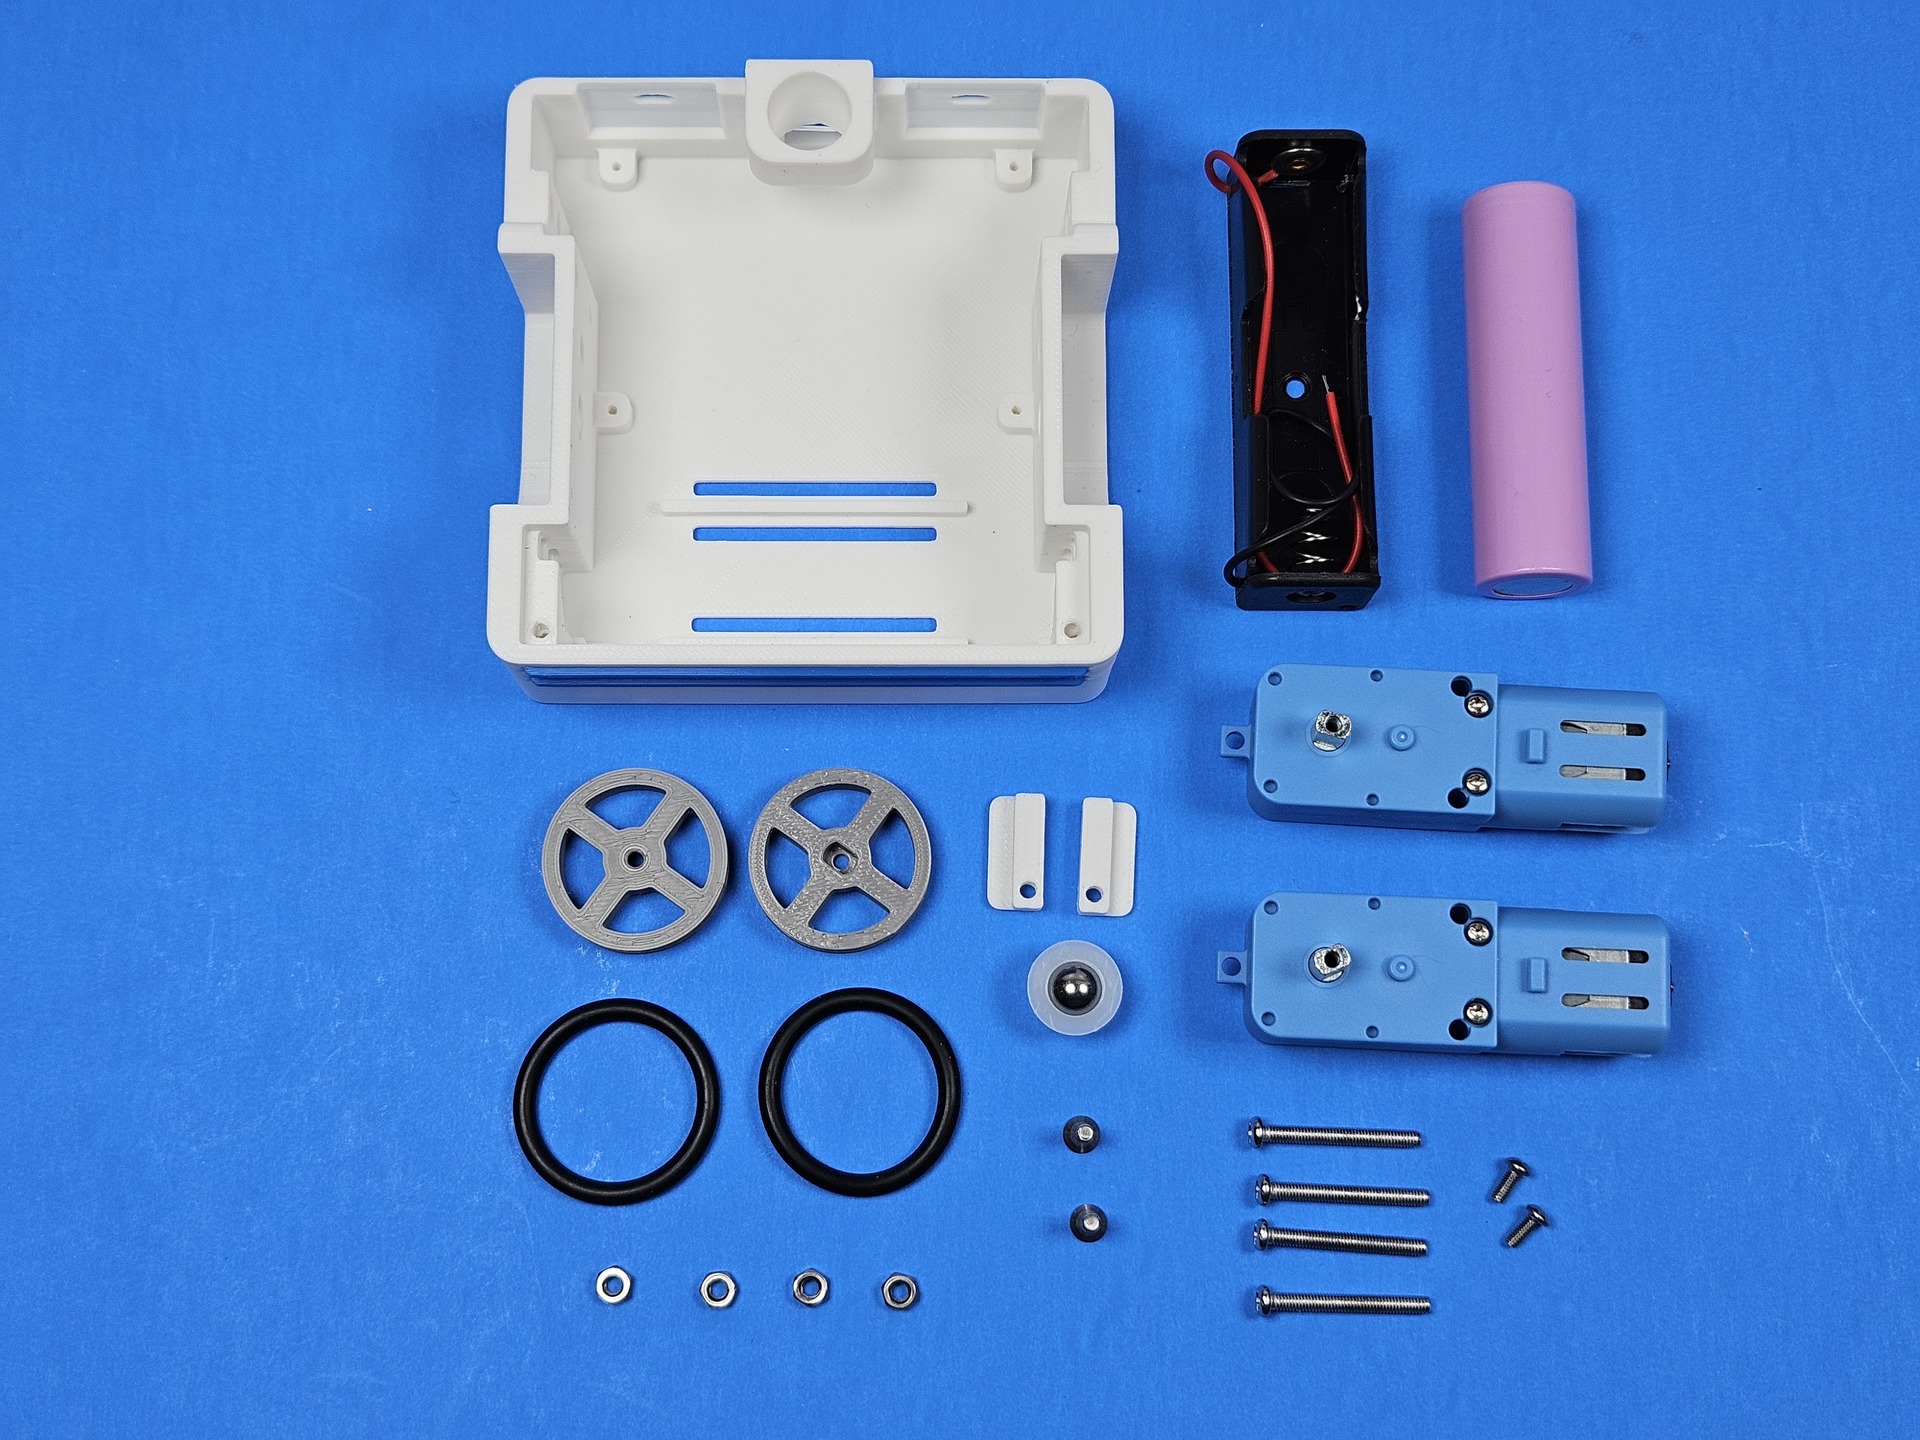
Parts Kit
CLICK TO ENLARGE

Parts Kit

Shell, wheels, tires, motors, caster, cell, and fasteners before assembly.
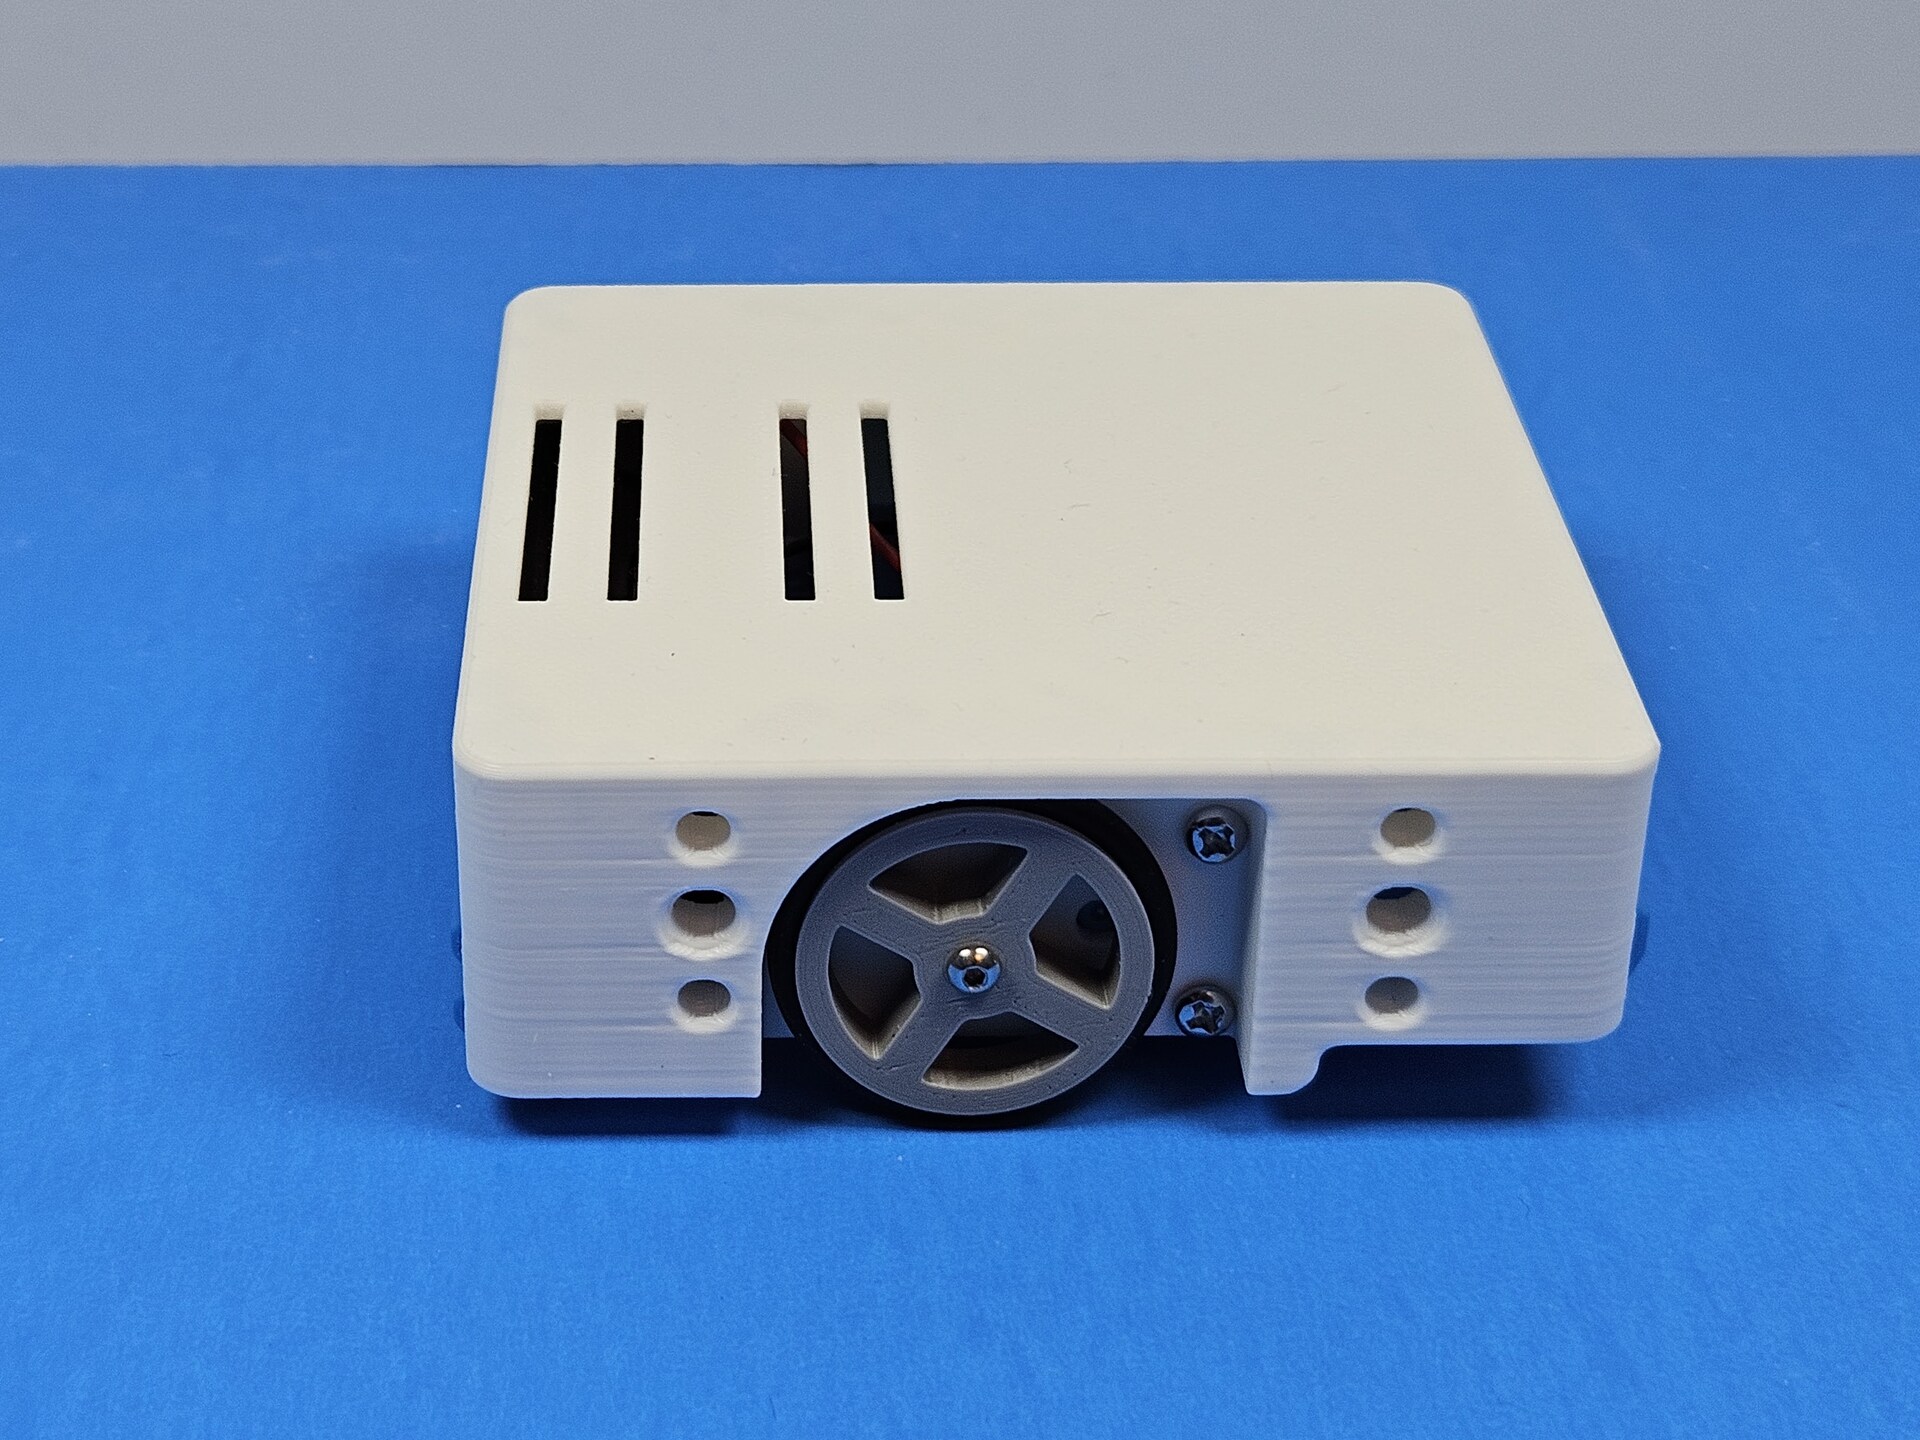
Closed Chassis
CLICK TO ENLARGE

Closed Chassis

The finished shell with a wheel sitting just proud of the body.
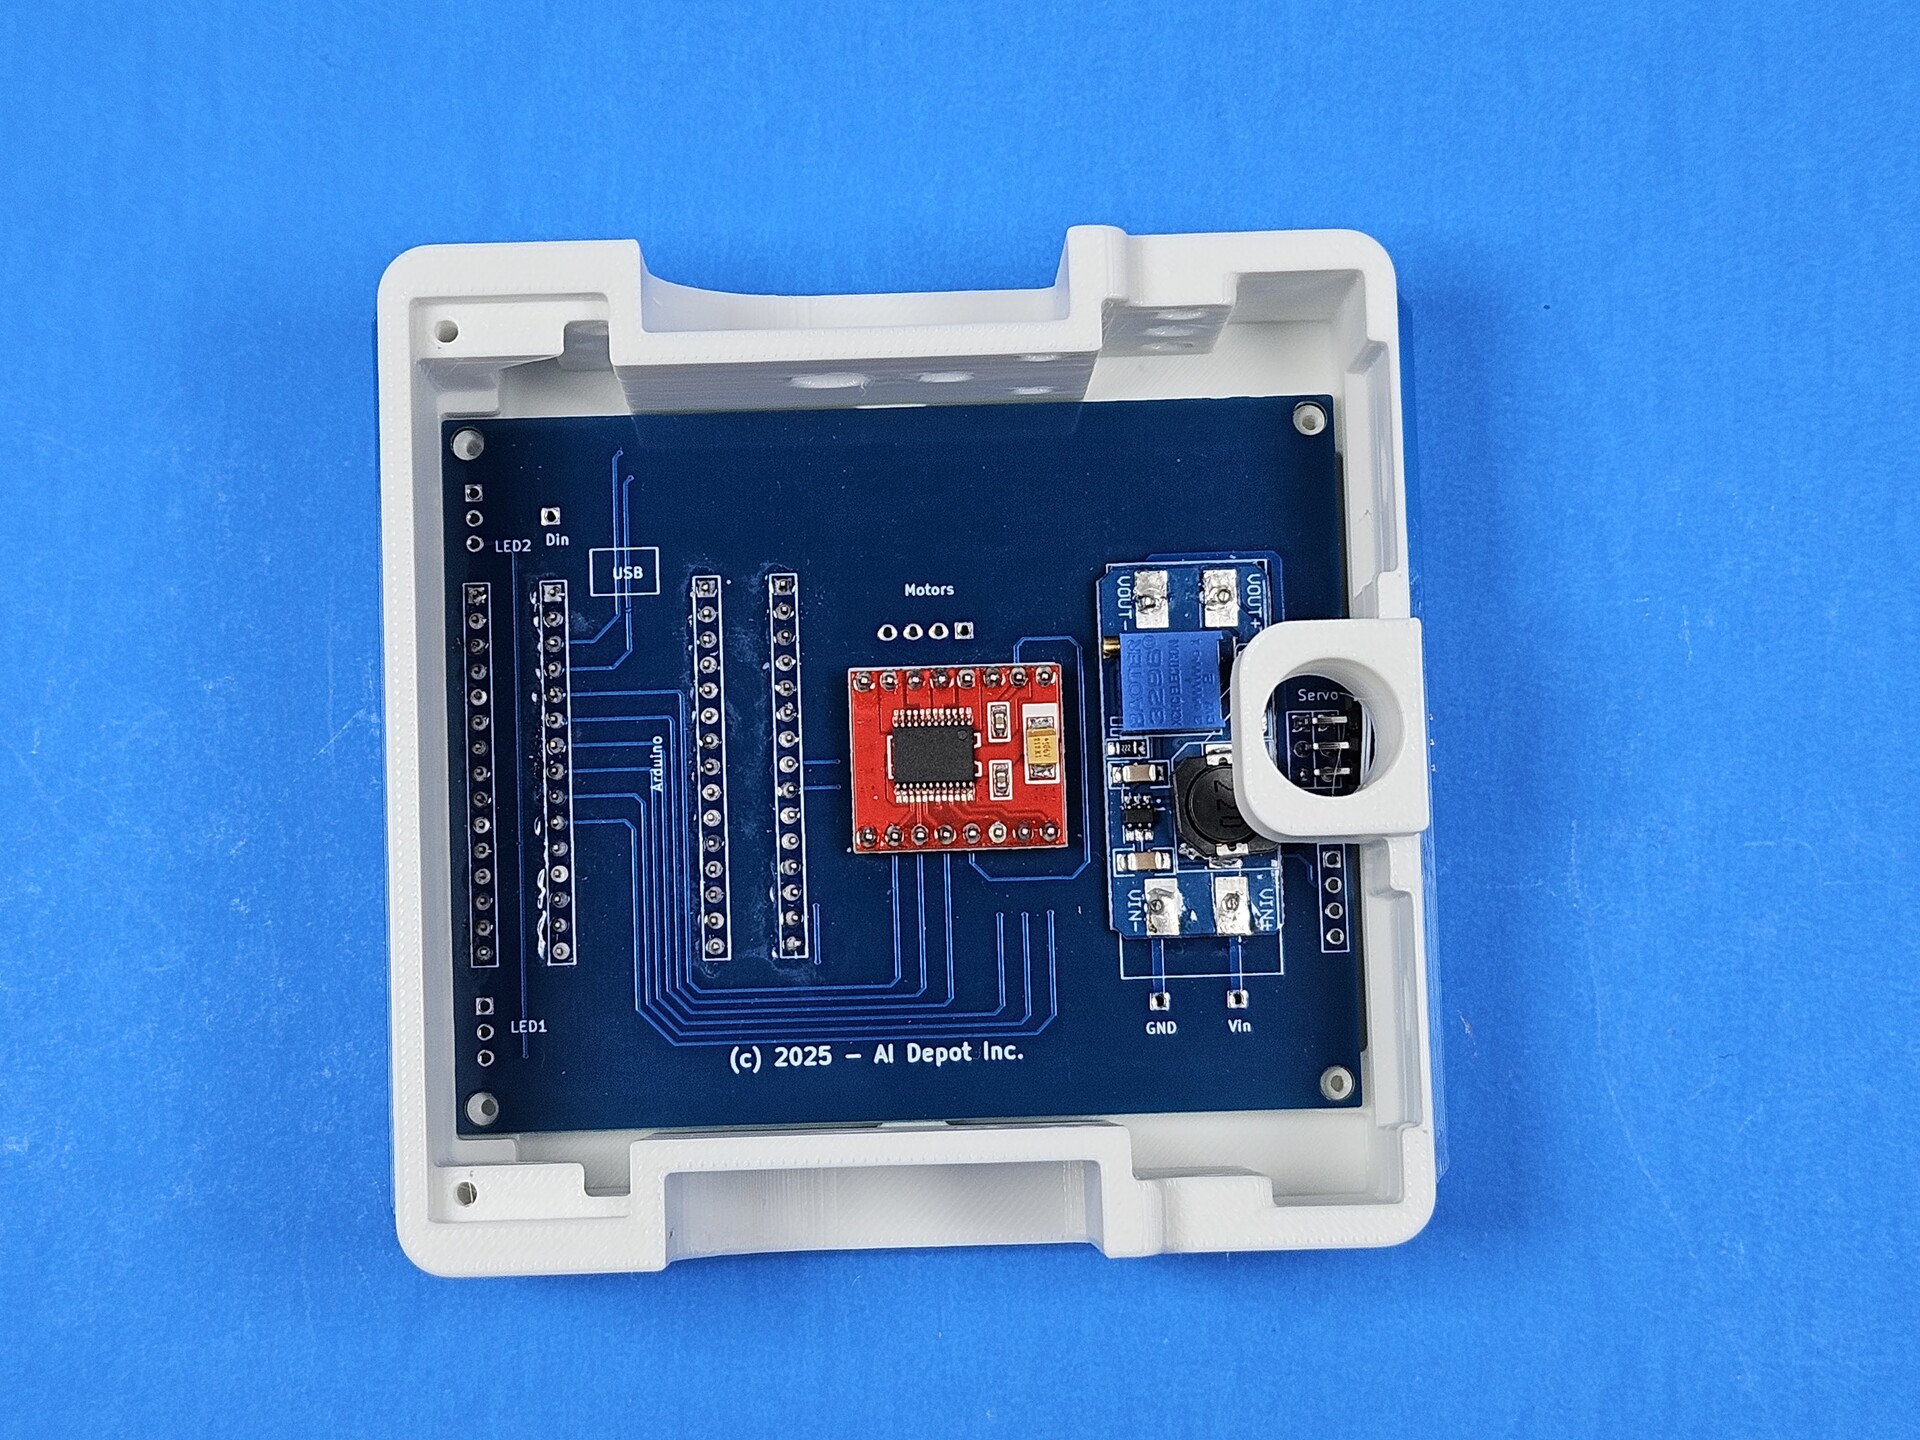
Driver Board
CLICK TO ENLARGE

Driver Board

The custom PCB seated in the printed shell.
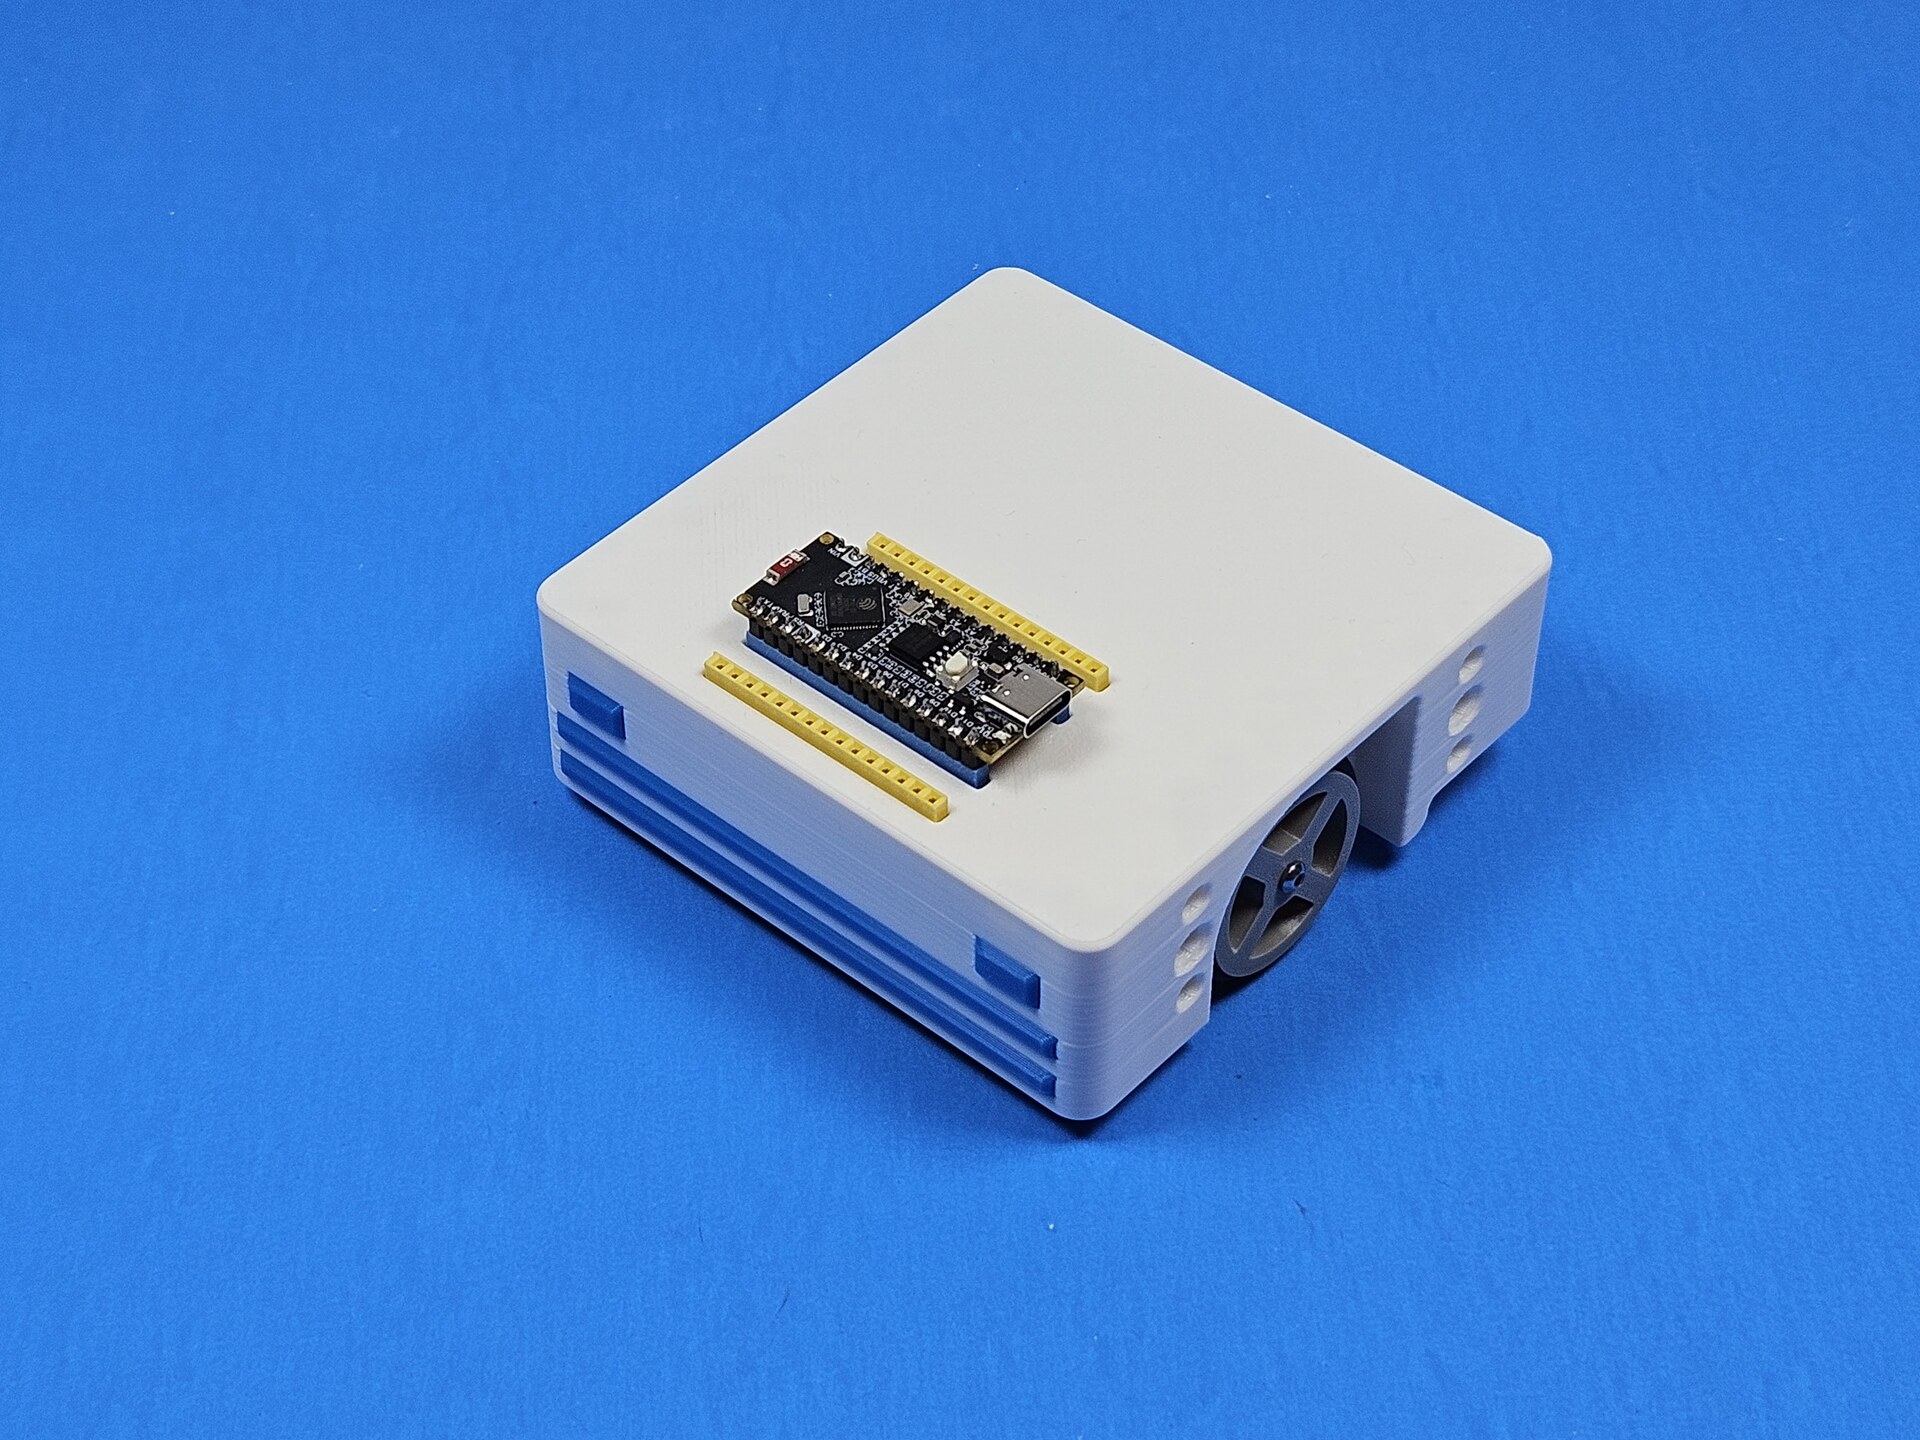
Top-Deck Nano
CLICK TO ENLARGE

Top-Deck Nano

The controller on headers so the robot can be programmed without opening the body.
Exterior CAD
CLICK TO ENLARGE

Exterior CAD

The closed body, vents, and one driven wheel in the model.
Board Layout
CLICK TO ENLARGE

Board Layout

Arduino, motor controller, converter, servo, and I2C on one board.

// SLIDESHOW

All Project Pictures

49 photographs and drawings from this build.

20250529_101808.jpg 1 / 49
20250529_101808.jpg
// TECHNICAL SPECIFICATIONS

System Parameters & Metrics

PARAMETER SPECIFICATION / VALUE
Platform Differential-drive mobile robot
Drive Two gear motors and a ball caster
Energy 18650 cell and holder
Controller Arduino-compatible Nano on headers
Driver Board Custom PCB marked AI Depot Inc.
Board Interfaces Motor driver, DC-DC converter, servo header, I2C
Chassis 3D-printed shell, CAD revision V4