ANTHONY NISTOR // DIGGER

Stackr Digger

A front add-on for Stackr that shows a parallelogram bucket, servo control from an Arduino Nano ESP32, and driving the arm from a phone gamepad.

// SYSTEM ARCHITECTURE

How the Bucket Stays Level

Two long links run side by side from the red frame to the bucket. They form a parallelogram, so the bucket keeps its angle while the arm lifts. A shorter link and a servo horn tilt the scoop. An Arduino Nano ESP32 on Stackr drives the servos, and the SPad745 phone app sends those moves from a gamepad on the screen.

  • Parallelogram Arm The two long links stay parallel. Raising the arm lifts the bucket without tipping it, and a short link curls the scoop.
  • Nano ESP32 Servos Two micro servos sit in the frame. The Arduino Nano ESP32 on the robot sets their positions.
  • Phone Gamepad The SPad745 app puts a D-pad, two sticks, and face buttons on the phone and uses them to command the digger.
DIGGER_ARM.LOG ACTIVE
1. PAD

The phone gamepad sends a move

APP
↓ Set the servo angles
2. NANO

The Arduino Nano ESP32 drives the servos

PWM
↓ Raise or curl the scoop
3. ARM

The parallelogram lifts the bucket and keeps it level

LIFT
// DIGGER RUN

Digger Demo

The arm lifting and the bucket moving on Stackr.

DIGGER_DEMO.MP4 LIVE DEMO

Arm in Motion

This recording shows the digger in operation, with the parallelogram raising the bucket.

// HARDWARE & SOFTWARE

System Component Breakdown

01

Parallelogram

Two long links, a short curl link, and the bucket. The parallel links keep the scoop from tipping as it rises.

02

Micro Servos

A pair of servos in the frame. The parts laid out for the build are MG90S metal-gear servos.

03

Arduino Nano ESP32

The controller on top of Stackr. It takes the gamepad commands and sets the servo positions.

04

SPad745

A RobotiX One phone screen laid out like a gamepad: D-pad, sticks, A B X Y, and the shoulder buttons.

// PROJECT MEDIA

Build Photos

The printed parts, the arm on Stackr, the phone gamepad, and the CAD model.
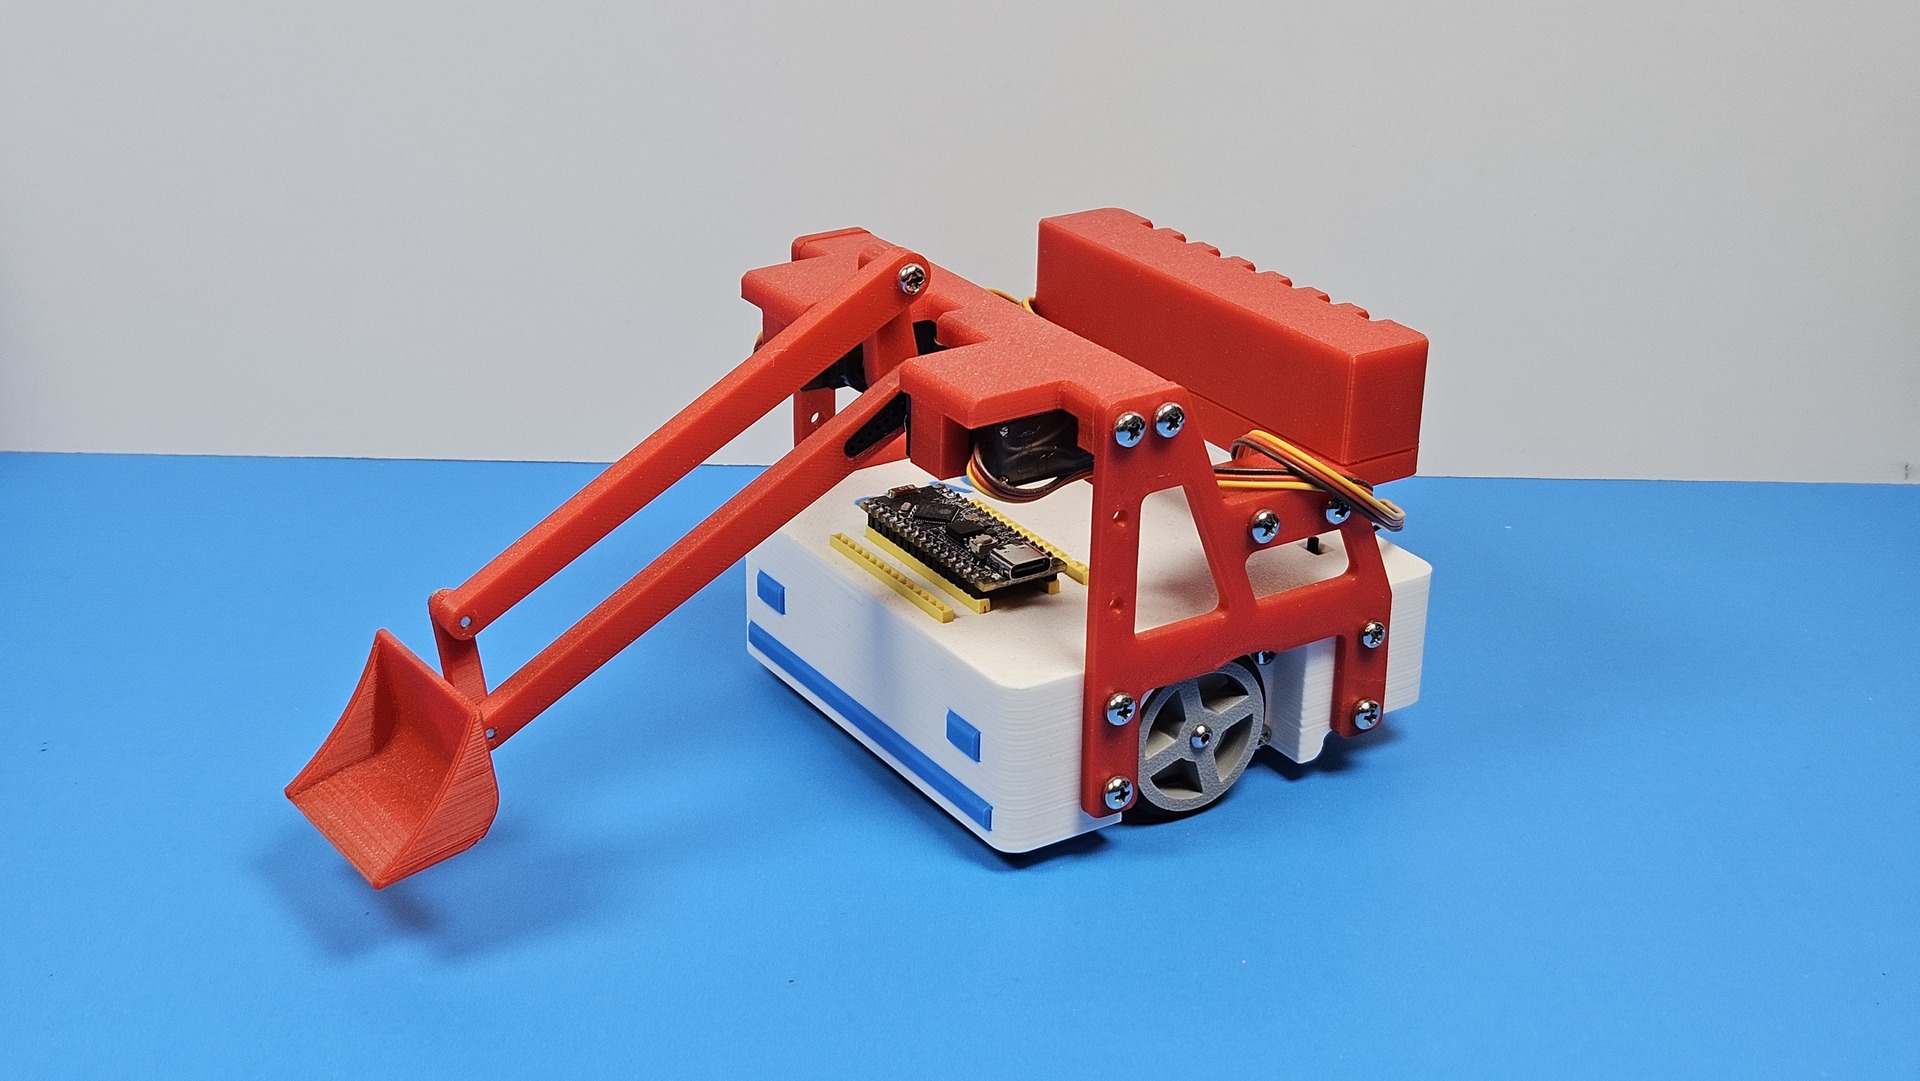
On Stackr
CLICK TO ENLARGE

On Stackr

The red digger bolted to Stackr, with the Nano ESP32 between the side frames.
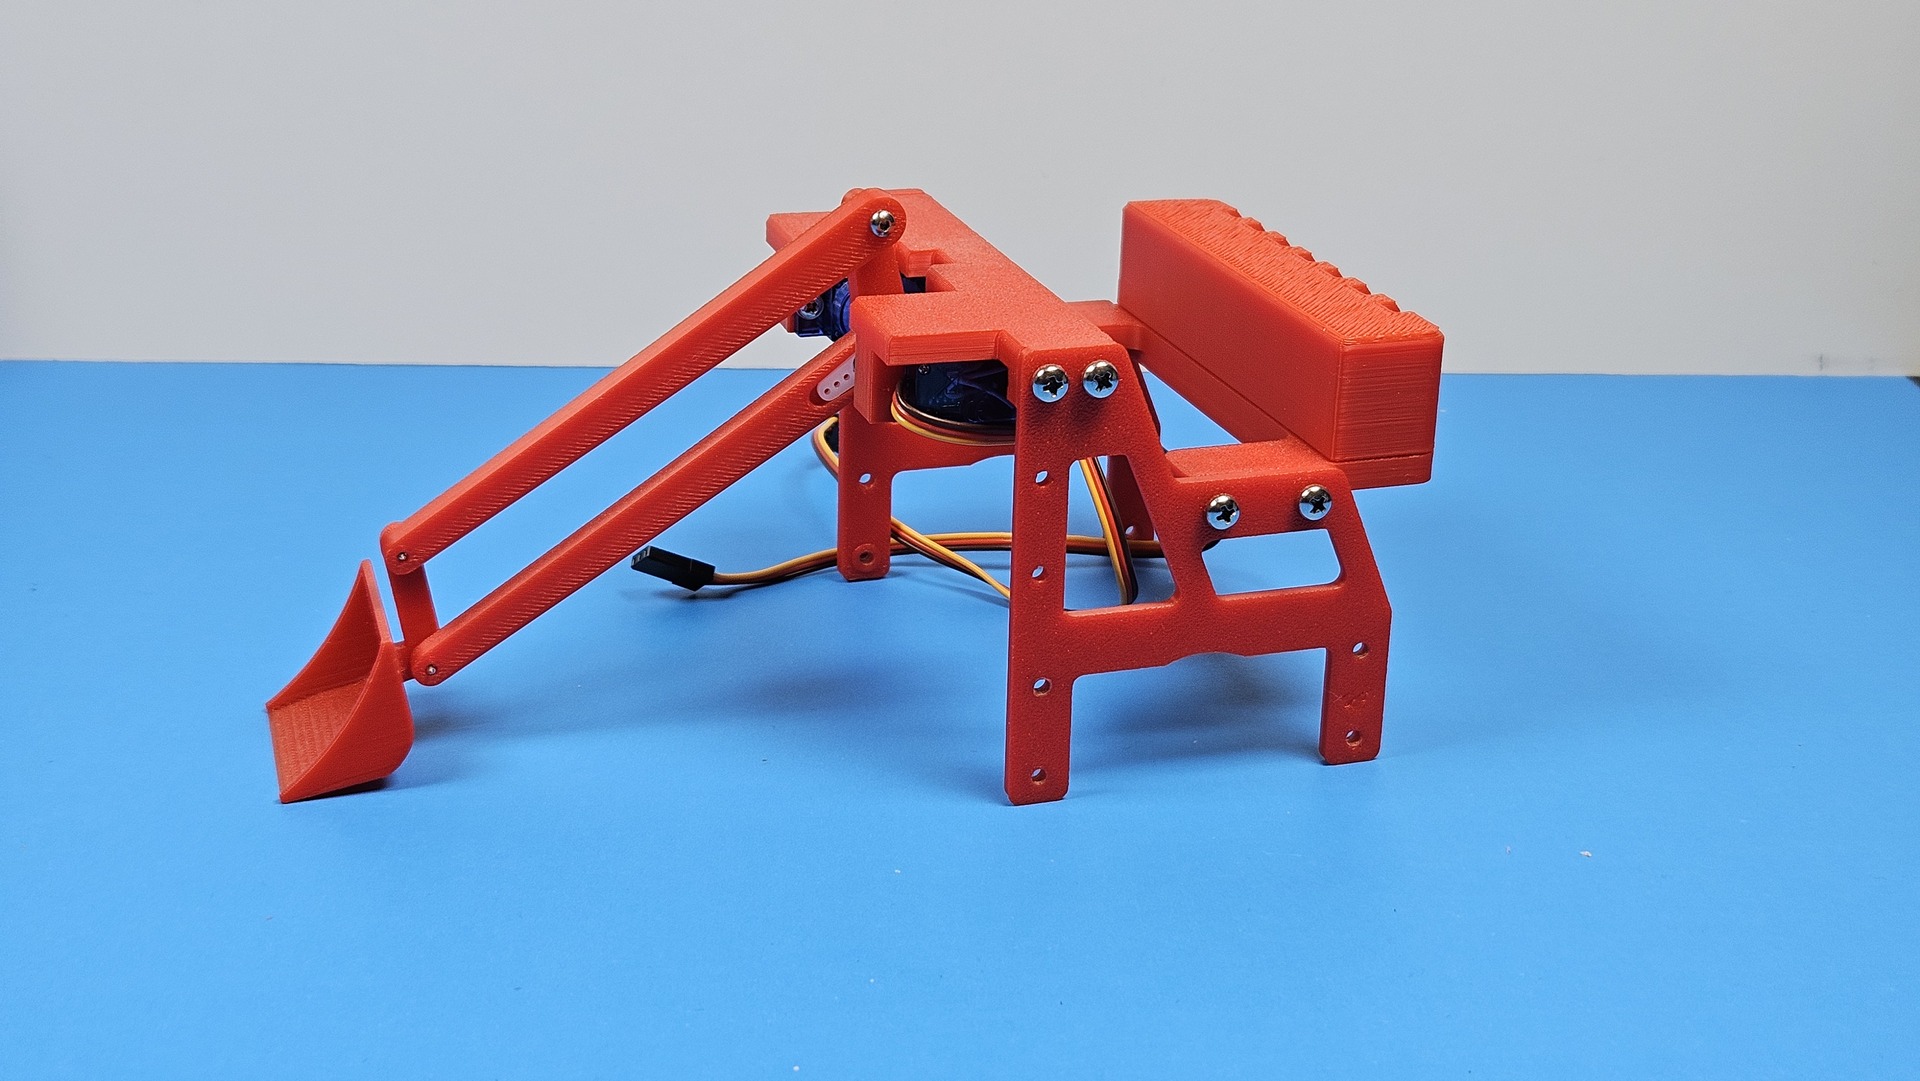
The Linkage
CLICK TO ENLARGE

The Linkage

The parallelogram, bucket, servos, and rear counterweight without the robot.
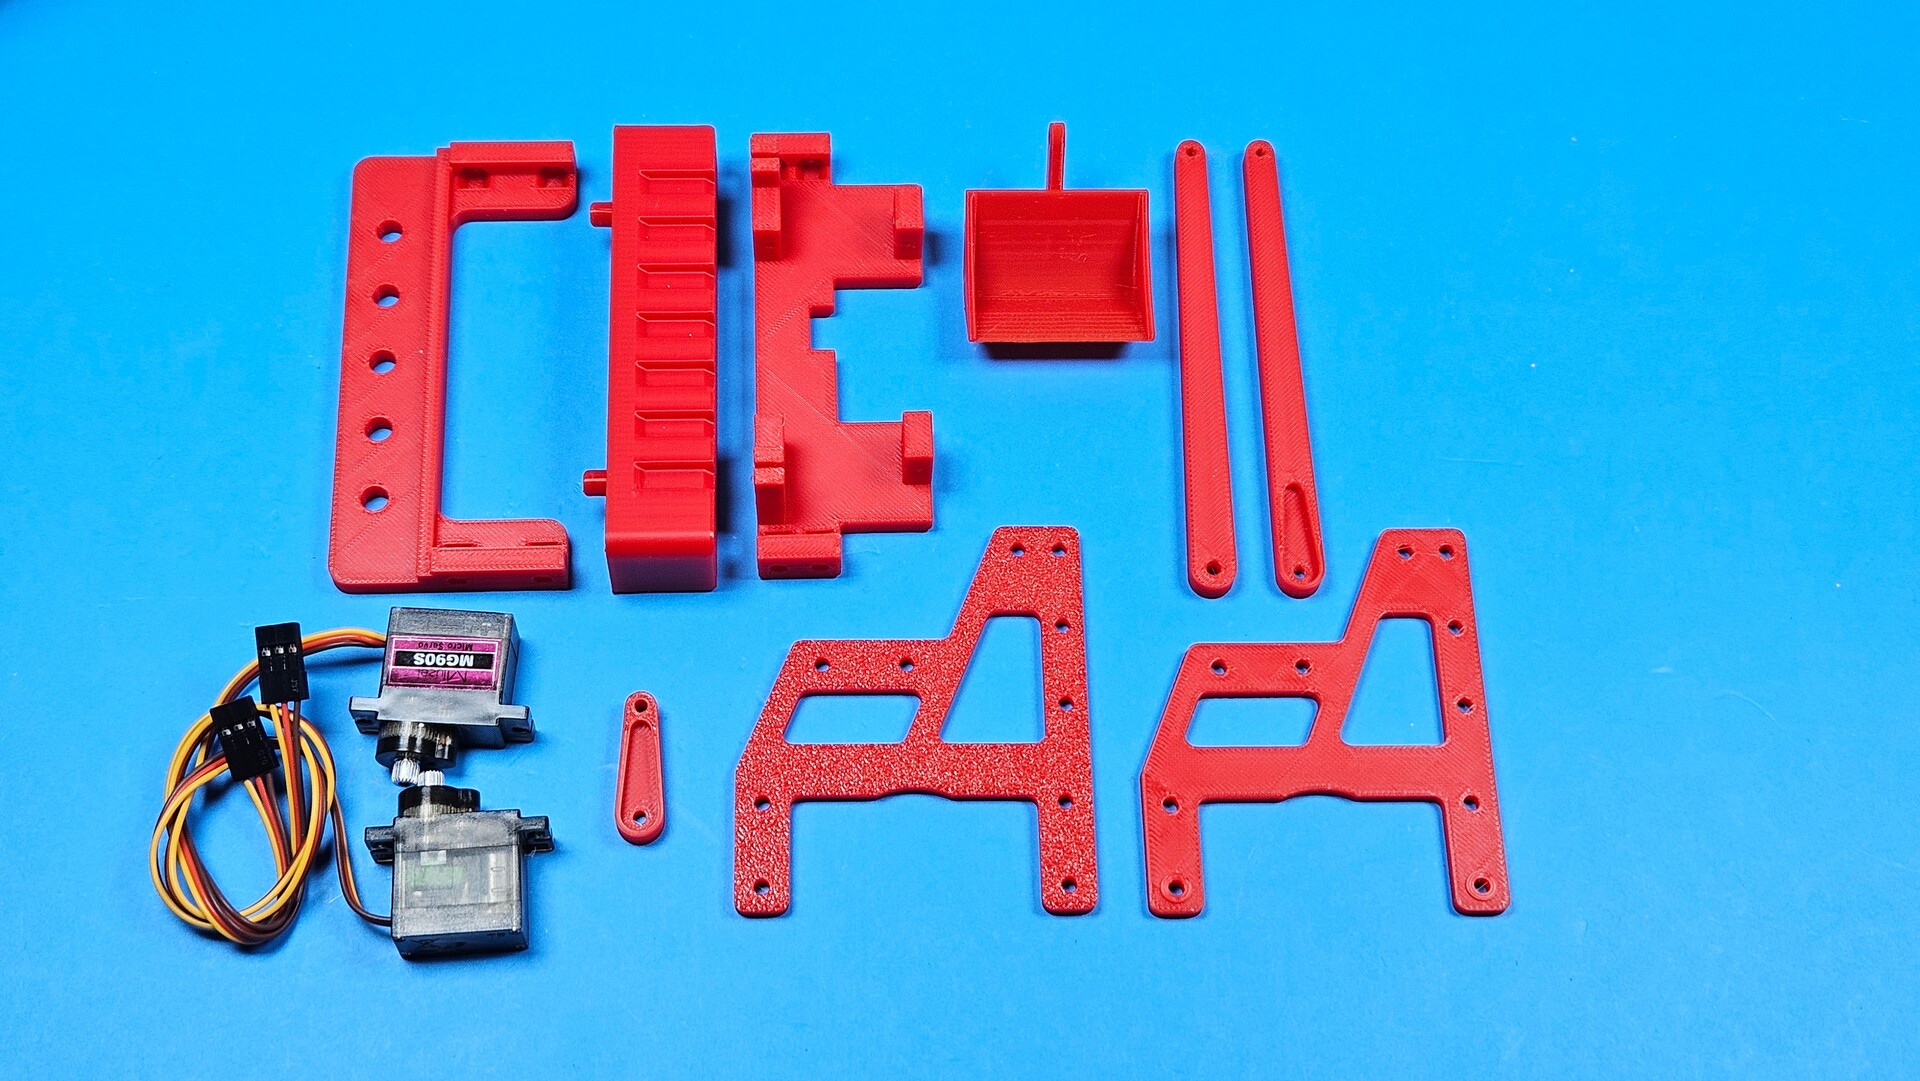
Printed Parts
CLICK TO ENLARGE

Printed Parts

Side frames, links, bucket, and the two servos before assembly.
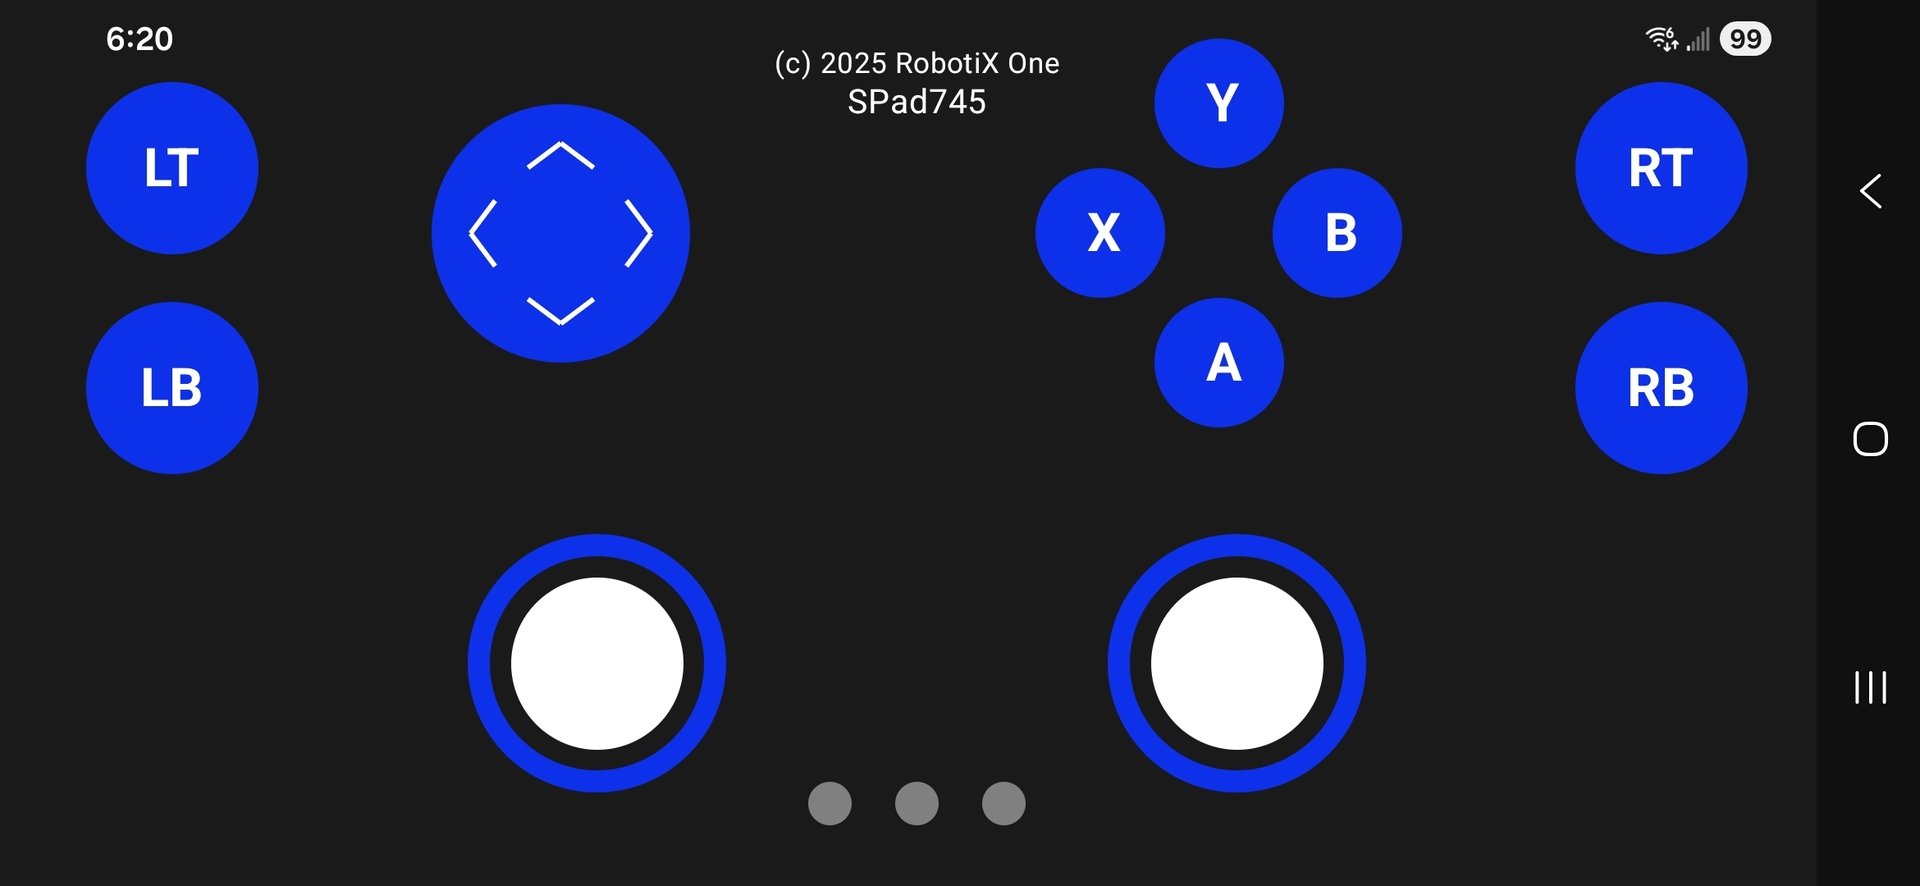
Phone Gamepad
CLICK TO ENLARGE

Phone Gamepad

The SPad745 screen, with a D-pad, two sticks, and the face and shoulder buttons.
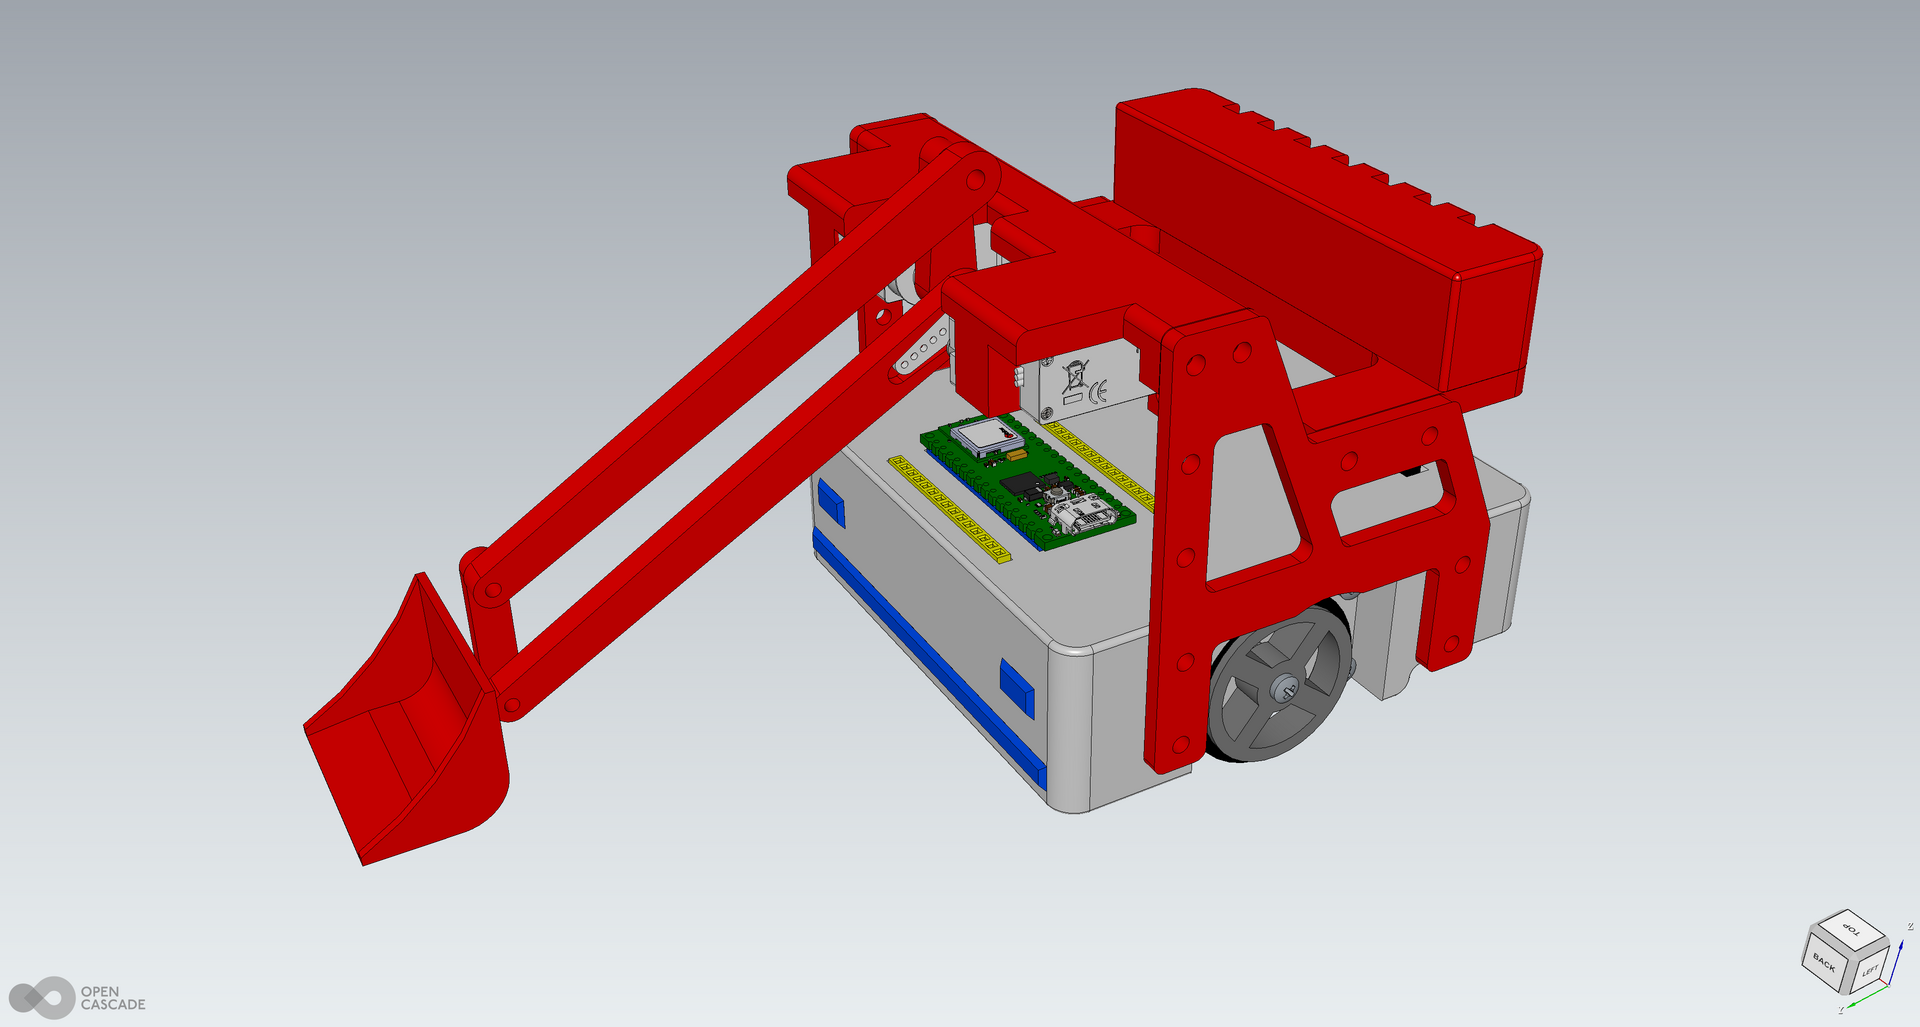
CAD on Stackr
CLICK TO ENLARGE

CAD on Stackr

The FreeCAD model of the digger mounted on the robot.
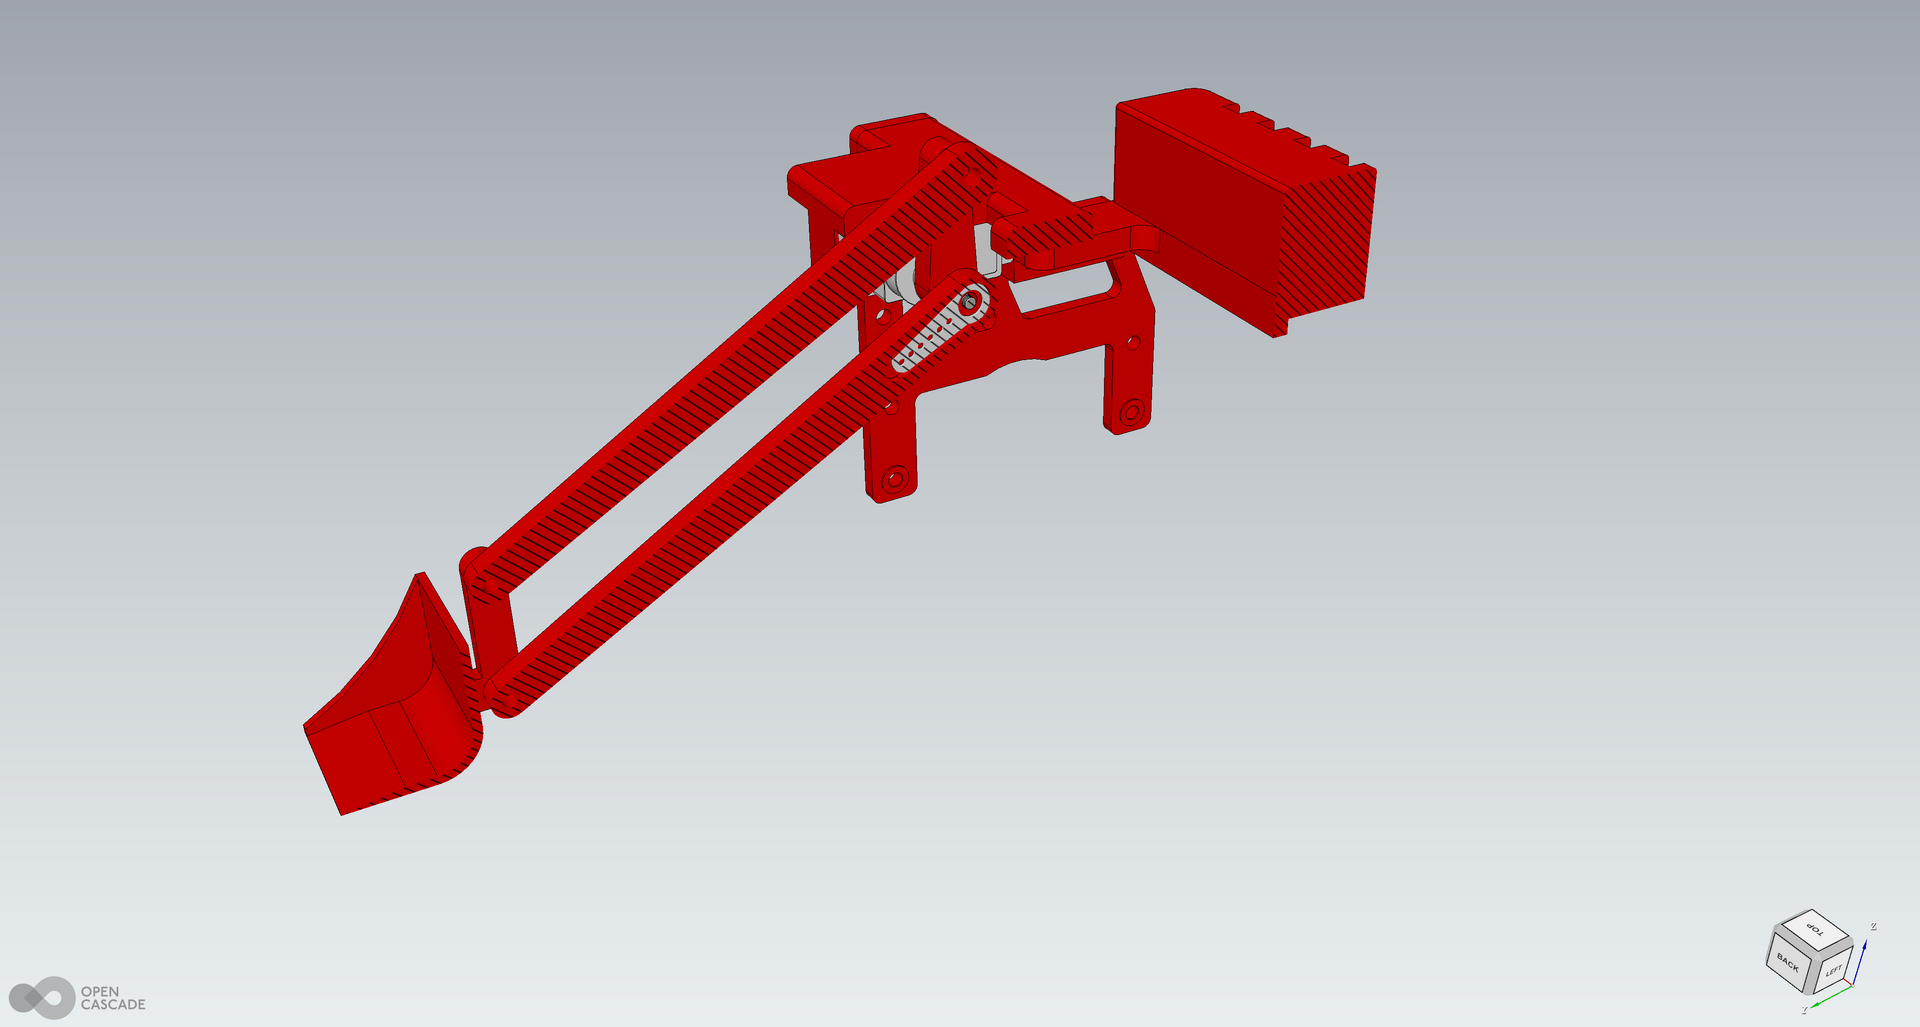
Arm Model
CLICK TO ENLARGE

Arm Model

The linkage by itself: long links, curl link, bucket, and counterweight.
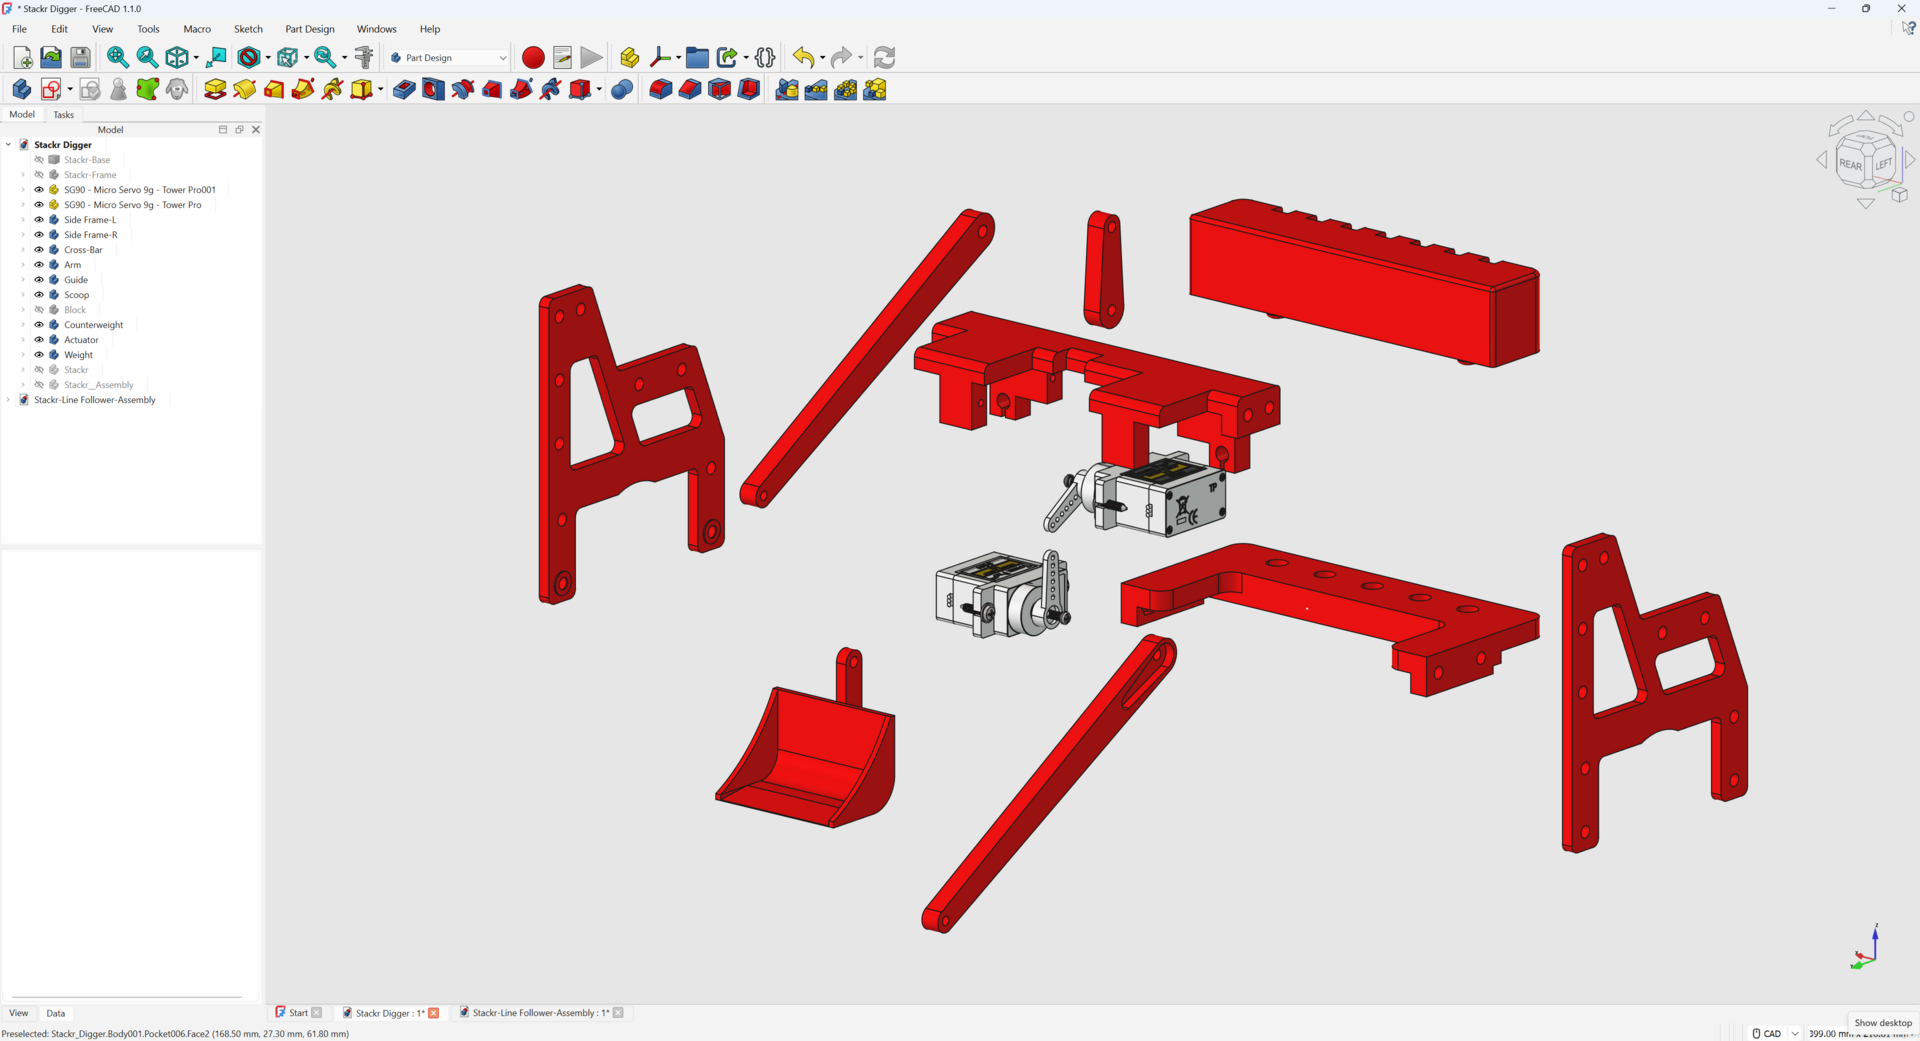
Exploded Parts
CLICK TO ENLARGE

Exploded Parts

The FreeCAD model pulled apart: frames, links, bucket, counterweight, and the two servos.

// SLIDESHOW

All Project Pictures

12 photographs and drawings from this build.

20261013_184559~2.jpg 1 / 12
20261013_184559~2.jpg
// TECHNICAL SPECIFICATIONS

System Parameters & Metrics

PARAMETER SPECIFICATION / VALUE
Host Stackr
Mechanism Parallelogram arm and bucket
Servos Two micro servos; the build parts are MG90S
Controller Arduino Nano ESP32
App SPad745 phone gamepad
Structure Printed red frames, links, bucket, and counterweight
Design FreeCAD assembly